Problem. Delivery robots get stuck at crosswalks: they spin in place, miss the walk phase, or start into traffic.
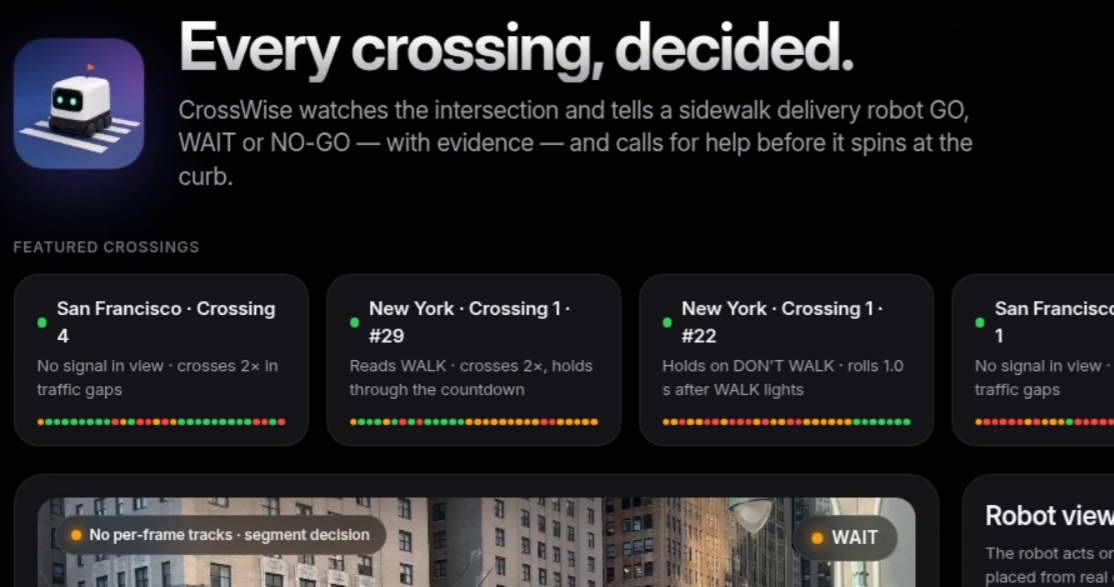
What it does. CrossWise watches street video and decides GO, WAIT or NO-GO every 0.2 seconds, with the evidence drawn on the video. When a robot would wait too long, it escalates to a reroute or a remote operator. A scorecard ranks 7 crossings by difficulty for route planning.
How it works. Vehicles are tracked from the YOLO11 boxes VAST stores for every frame, with camera-shake removal and 1.5-second path prediction. The pedestrian signal is read from pixels. A vision model on W&B Inference finds cones, barriers and the free path. Unclear evidence forces WAIT. NVIDIA Cosmos Reason captions and Cosmos Embed search, on CoreWeave GPUs, found the crossing footage in the VAST archive. Decisions are stored in VastDB and model calls are traced in W&B Weave.
What we learned
 SpaceXAI (Cursor)
 CoreWeave (Weights & Biases)
 NVIDIA