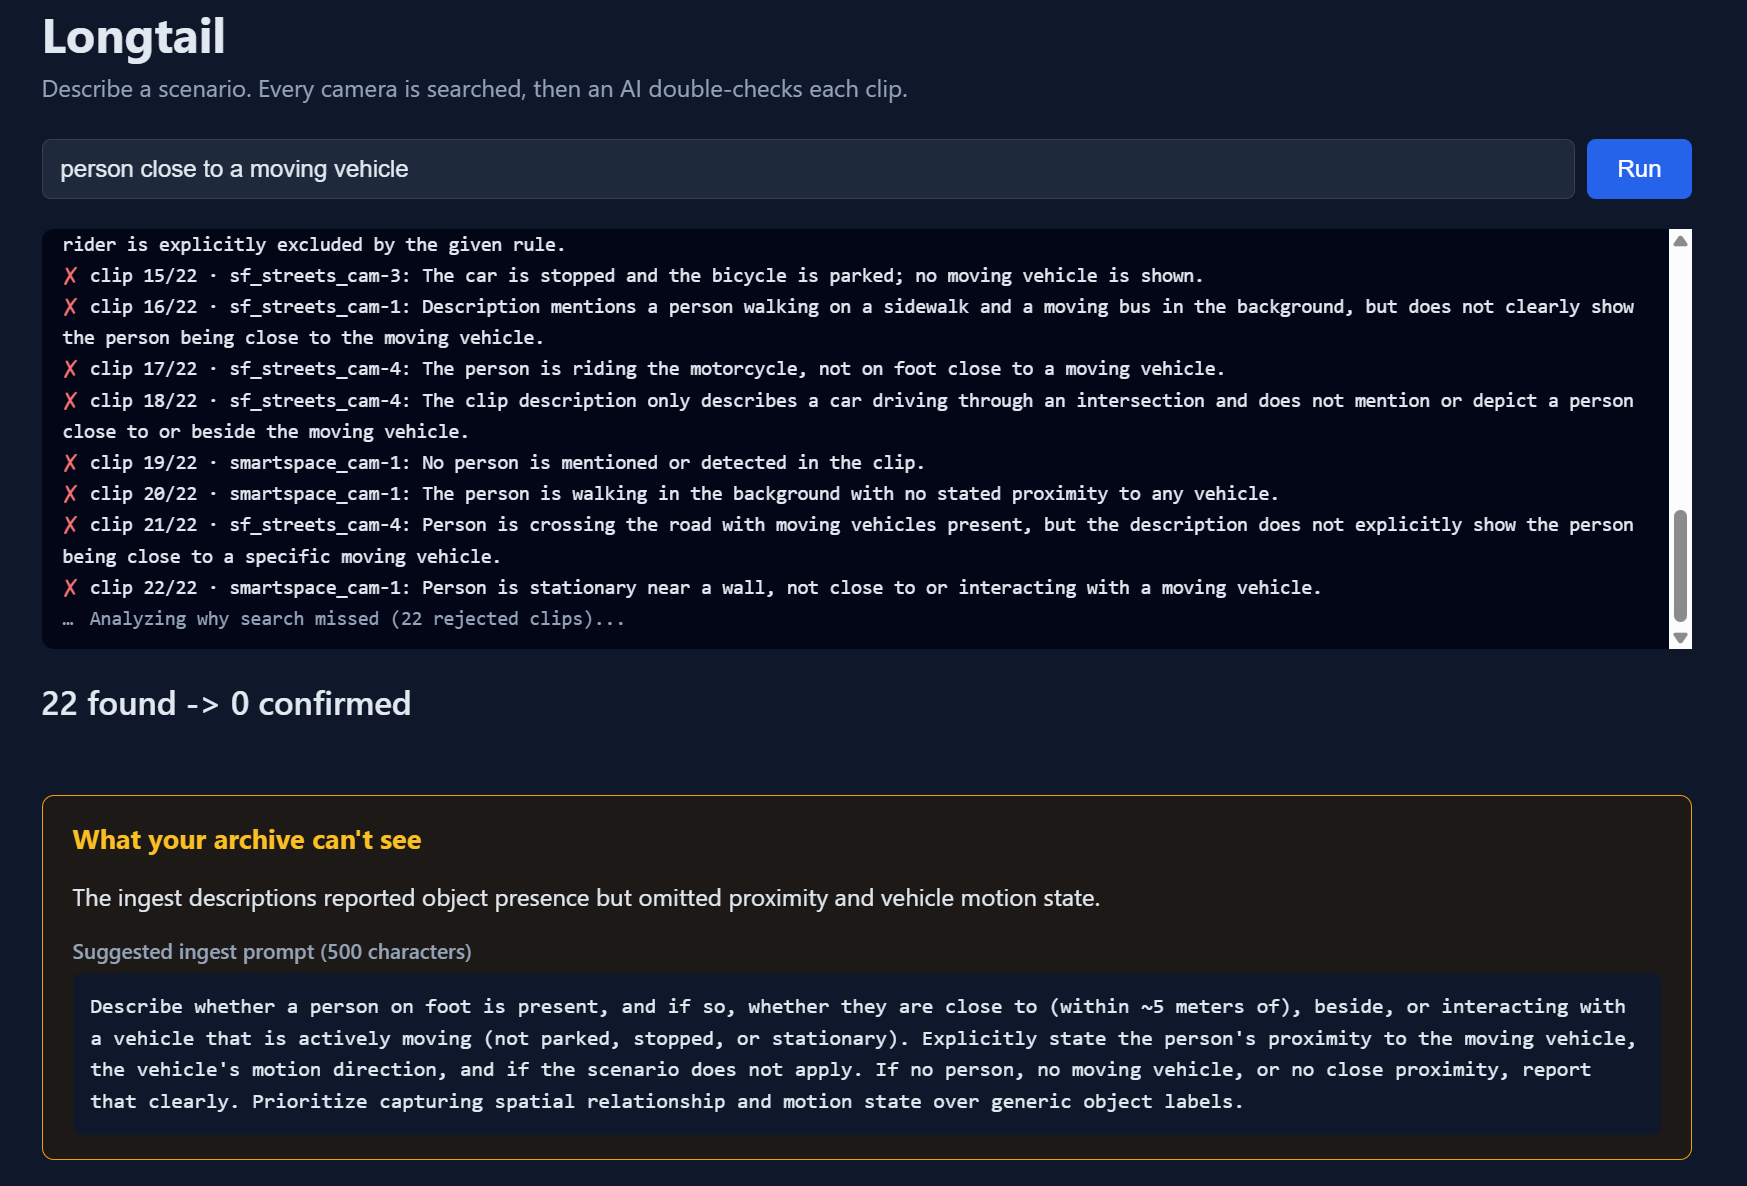
You describe a scenario in plain words (e.g. "person close to a moving vehicle"). LongTail searches every camera separately in the VAST/VSS archive (Cosmos3-Reason descriptions, Cosmos Embed1 vectors, YOLO11 detections), then sends each hit to NVIDIA Nemotron 3.5 Lightning on W&B Inference for a yes/no/unsure verdict with a reason. The page shows verdicts live, plays confirmed clips and saves them as a test set. After each run, a second W&B call reads the rejection reasons, explains what the archive's descriptions fail to capture, and suggests a better Cosmos ingest prompt. Example: 22 search hits -> 1 confirmed (a person running toward a moving forklift); the descriptions never state distance between people and moving vehicles. Built solo with the Cursor Agent CLI and the event skills, deployed on CoreWeave Kubernetes; Weave traces verdicts from the CLI. Limits: verdicts use text descriptions, not pixels; borderline verdicts can change between runs; runs take 1-3 minutes.