tokens&
BrowseFor enterprises
tokens&

Find tools, check provider offers, save a build plan, and share your work when you’re ready.

For buildersFor enterprises

For builders

  • Startup credits and perks
  • Agent Skills
  • Publish a project

For enterprises

  • Start free company workspace
  • Submit a tool, product, or perk

Community

  • Community
  • Newsletter
  • Events
Xin

© 2026 tokensand, LLC. All rights reserved.

  • Terms
  • Privacy
  • Security
  • Data Processing
  • Status
  1. Hackathon
  2. Project gallery
  3. Ranger Duck
iverson930gabout 10 hours agoContributorJudging locked: Event build

Ranger Duck

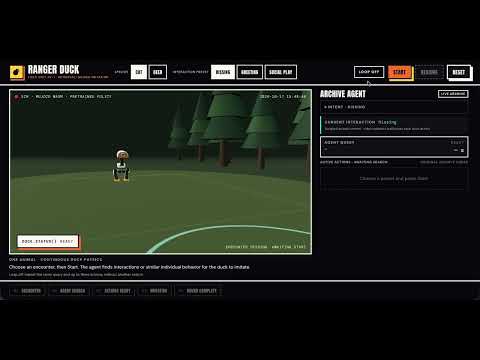
Ranger Duck is a robot prototype built with Pollen Robotics’ simulator and MuJoCo physics engine, using real animal videos to train AI agents to respond naturally, interact with animals, observe wildlife over time, and engage with pets while tracking their activities.

Review the project

Start with the source code, then open the demo or video if available.

View GitHub repository
Visit project website
Demo video
Watch demo video
Project description
What We BuiltMicroDuck uses real-world animal videos to guide a simulated robot’s responses, combining video search, playback, agent-driven actions, and physics simulation. We ingested three Hugging Face datasets totaling X minutes of video. Why It MattersRobot training needs diverse interaction data. MicroDuck explores using animal videos as behavioral references for embodied AI. Potential applications include long-term, close-range wildlife observation and pet companionship. How It WorksEncounter Mode: Retrieve an interaction video, use one animal’s behavior as the situation and the other’s as a response reference, then execute MicroDuck’s closest supported action.Loop Mode: Turn each completed action into the next search prompt and repeat.The agent harness coordinates retrieval, interpretation, action selection, and execution feedback, using existing pretrained movement policies to explore future training workflows. Technology
Tools used
  • VAST Data logoVAST Data
  • CoreWeave (Weights & Biases) logoCoreWeave (Weights & Biases)
  • NVIDIA logoNVIDIA
Watch demo video
Project gallery
Simulation:
Pollen Robotics’ MicroDuck simulator, MuJoCo WebAssembly physics, Three.js rendering, and ONNX Runtime Web movement policies.
Agent and evaluation:
Codex with MCP search tools; Weights & Biases for tracing and evaluation.
Video infrastructure:
VSS, VastDB, and S3 for searchable clips, captions, metadata, detections, and playback; VAST DataEngine with Cosmos3-Reason, YOLO11, and Cosmos Embed1 for descriptions, detections, and embeddings.
Application:
React and TypeScript frontend with a Python FastAPI backend.
Project links
  • GitHub repository
  • Project website
  • Demo video
Tools used
  • VAST Data logoVAST Data
  • CoreWeave (Weights & Biases) logoCoreWeave (Weights & Biases)
  • NVIDIA logoNVIDIA