The problem: London has 25,000 bus drivers, and TfL's goal is that no one is killed on or by a London bus by 2030. Buses already carry cameras, but the footage is usually only pulled after something goes wrong. Nobody has time to watch it all, so the near misses that come before a crash, and the patterns behind them, go unseen. Safety teams often learn about a risky junction or habit only after someone is hurt.
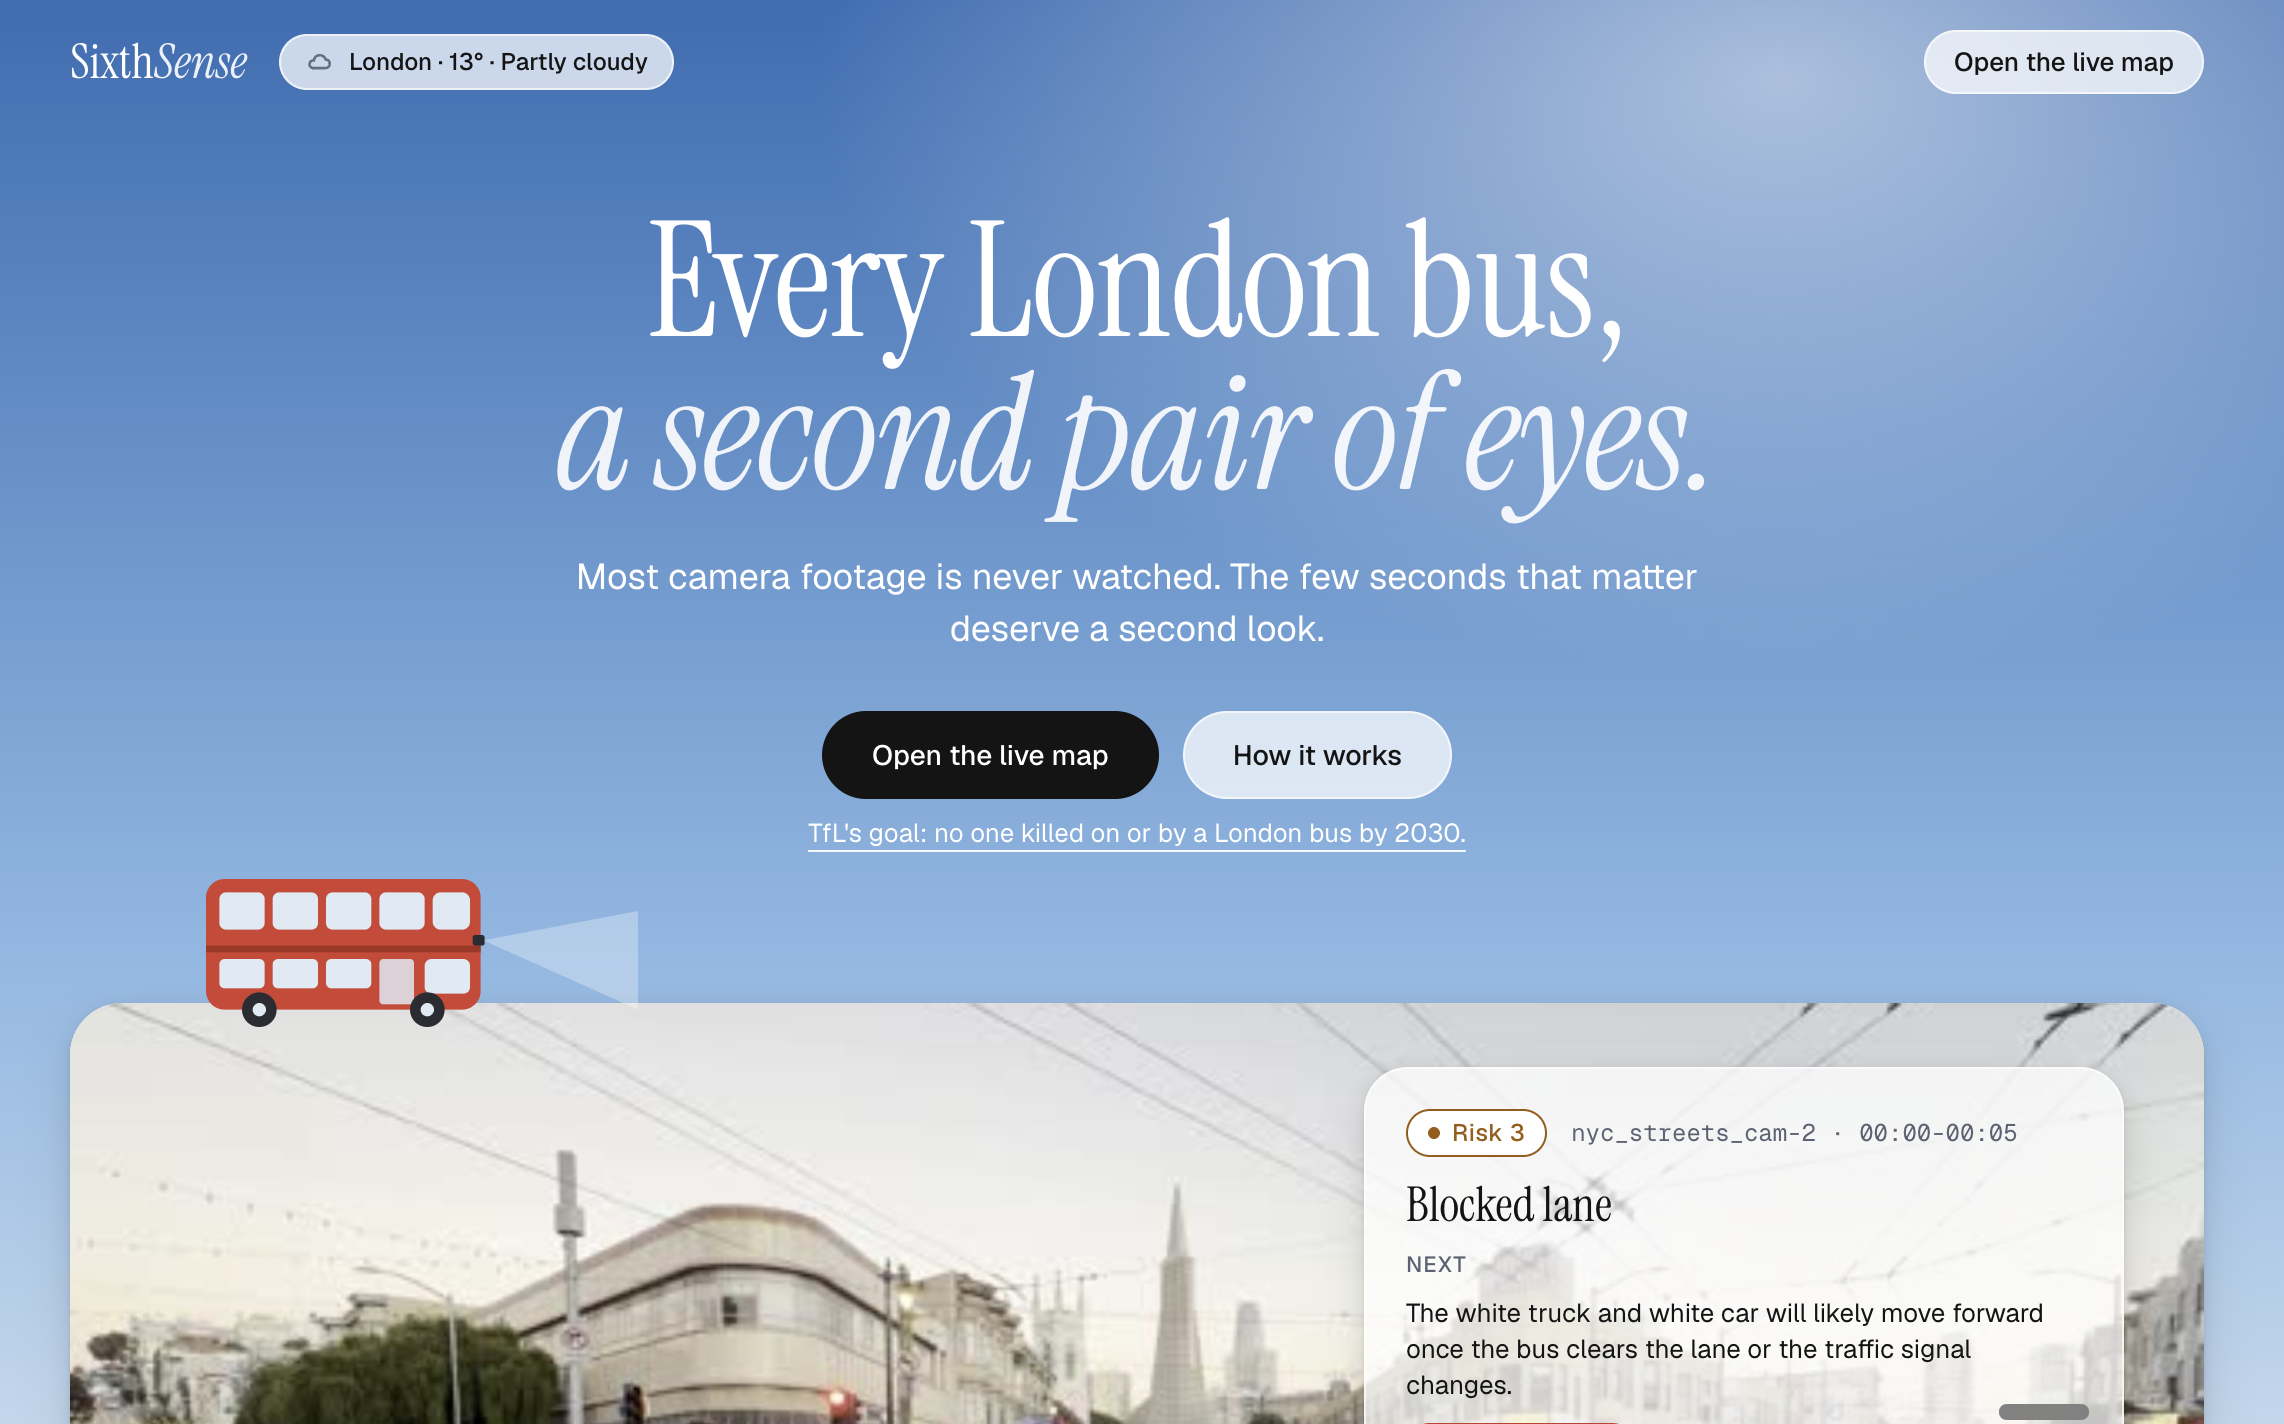
SixthSense helps London bus safety team see which buses had a close call and what to do about it.The live map shows every London bus from TfL open data, but only draws the buses that need a look, in order of risk.
For each camera clip, SixthSense:
- searches VastDB for 8 kinds of bus hazard, like a cyclist on the nearside or a pedestrian stepping out
- checks with YOLO11 boxes for annotations, object recognition that road users are really getting closer, and drops false alarms
- asks NVIDIA Cosmos3-Reason on CoreWeave what happens next, why, and what the driver should do
- watches the next clip and scores its own prediction with a model on W&B inference, with every step traced in Weave
Note: bus positions are live TfL data. The camera clips are the hackathon footage, standing in for bus cameras.
 CoreWeave (Weights & Biases)
 NVIDIA
 SpaceXAI (Cursor)